PrintExo
An open-source, shoe-agnostic, 3D-printable ankle exoskeleton platform for accessible locomotion research
📄 Paper Abstract (click to expand)
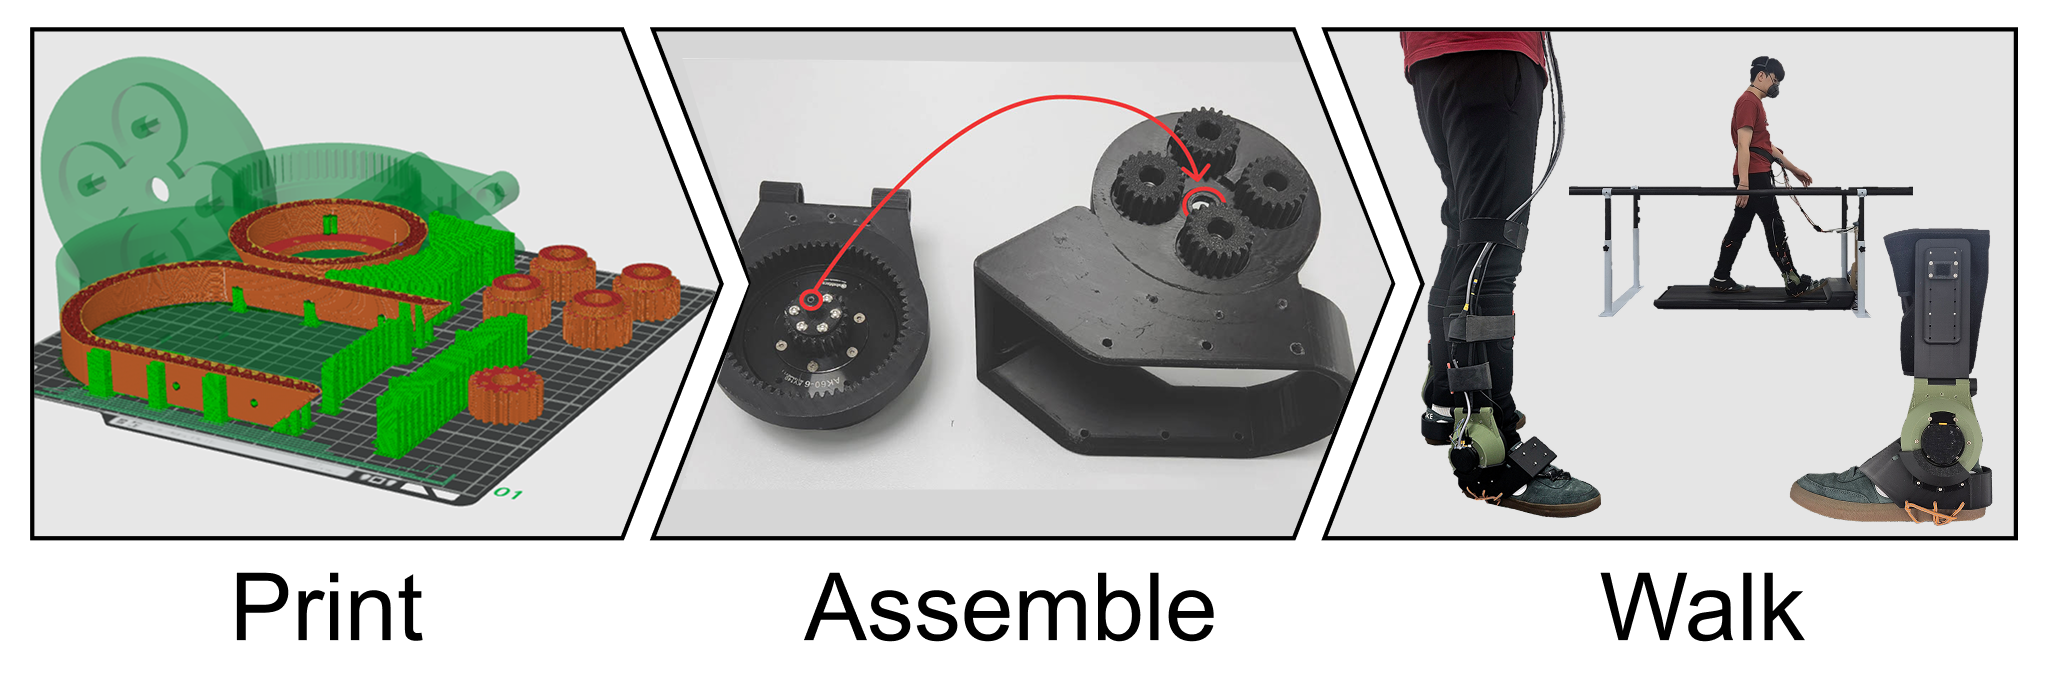
Wearable ankle exoskeletons are a key testbed for assistive control and human-robot interaction during locomotion, but many systems remain difficult to build and deploy due to fabrication and fitting overhead (e.g., CNC/composite processes, long lead times, and shoe-specific interfaces). We present PrintExo, an open-source, shoe-agnostic, fully 3D-printable ankle exoskeleton platform designed to lower the barrier to early-stage locomotion research and rapid prototyping. PrintExo can be fabricated using consumer-grade FDM printing and standard off-the-shelf components, and integrates a compact 3D-printed 1:4 planetary gearbox for ankle assistance (total assembled mass: 1.33 kg per leg, excluding the user’s shoe). A lace-anchored shoe interface transmits torque through commercially available lace-up footwear without permanent modification, enabling fast fitting across participants. The device was evaluated in a pilot treadmill study with five able-bodied participants walking at 1.0 m/s under three conditions: no-device, zero-torque, and powered assistance. Across completed sessions, powered assistance reduced metabolic cost relative to zero-torque, and encoder-derived kinematics captured device-side ankle motion during torque application. Overall, PrintExo provides a practical, low-overhead, open-source platform for accessible ankle-exoskeleton prototyping and pilot locomotion experiments.📄 Research Paper
⭐️ Key Features
- Fully 3D-printable structure using consumer-grade FDM printers
- Shoe-agnostic, lace-anchored interface with no permanent footwear modification
- Off-the-shelf hardware only, no custom machining
- Modular design for rapid prototyping and experimentation
- Open CAD and build documentation for reproducible use
📦 Open Resources
- 🔗 CAD, STL, and G-code
- 🔗 Assembly manual
- 🔗 Example Control demo scripts — coming soon
All resources will be released in a public repository.
⚠️ Disclaimer
PrintExo is a prototype research platform intended for pilot studies and educational use.
It is not a certified medical device, and its safety or clinical effectiveness has not been established.
PrintExo should not be used for diagnosis, treatment, rehabilitation, or unsupervised human assistance.
All experiments involving human subjects should follow your local Institutional Review Board (IRB) or equivalent ethics approval process.
✉️ Contact
For questions or collaboration:
Name:      Sunin Baek
Email:     suninbaek@korea.ac.kr
Affiliation: MINT Lab, School of Mechanical Engineering, Korea University
📑 Citation
If you use PrintExo in your work, please cite:
@unpublished{baek2026printexo,
  author = {Baek, Sunin and Lee, Yuhyeon and Hur, Benjamin and Cha, Eun Sang and Kim, Daekyum},
  title  = {PrintExo: An Open-Source, Shoe-Agnostic, 3D-Printable Ankle Exoskeleton for Accessible Locomotion Research},
  note   = {Manuscript submitted to IEEE RAS/EMBS International Conference on Biomedical Robotics and Biomechatronics (BioRob)},
  year   = {2026}
}